A journal of IEEE and CAA , publishes
high-quality papers in English on original
theoretical/experimental research
and development in all areas of automation
 Volume 13
Issue 10
IEEE/CAA Journal of Automatica Sinica
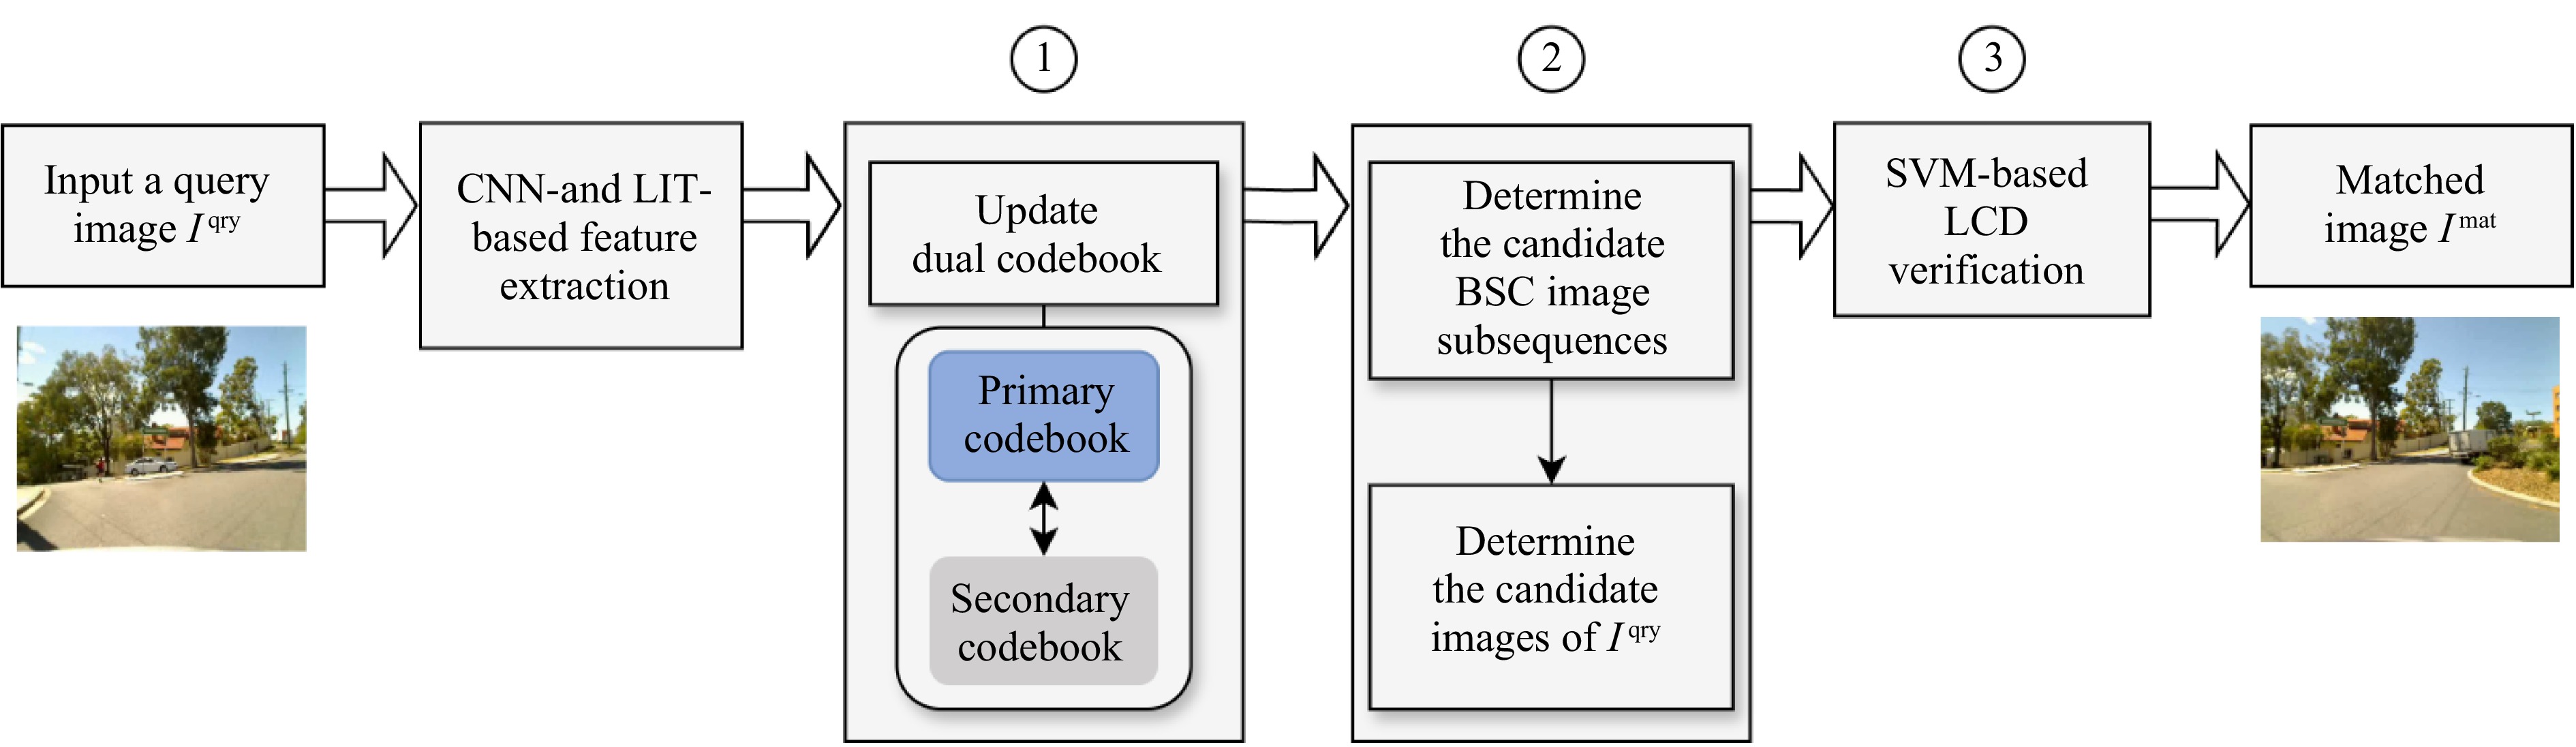
| Citation: | K.-L. Chung, Q.-H. Jian, and Y.-Q. Zhang, “Dual codebook- and scene change-based loop closure detection using SVM outlier removal in verification,” IEEE/CAA J. Autom. Sinica, vol. 13, no. 10, pp. 2312–2326, Oct. 2026. doi: 10.1109/JAS.2026.125762

|

| [1] |
A. J. Davison, I. D. Reid, N. D. Molton, and O. Stasse, “MonoSLAM: Real-time single camera SLAM,” IEEE Trans. Pattern Anal. Mach. Intell., vol. 29, no. 6, pp. 1052−1067, Jun. 2007. doi: 10.1109/TPAMI.2007.1049
|
| [2] |
J. Engel, T. Schöps, and D. Cremers, “LSD-SLAM: Large-scale direct monocular SLAM,” in Proc. 13th European Conf. Computer Vision, Zurich, Switzerland, 2014, pp. 834−849.
|
| [3] |
E. Garcia-Fidalgo and A. Ortiz, “Vision-based topological mapping and localization methods: A survey,” Robot. Auton. Syst., vol. 64, pp. 1−20, Feb. 2015.
|
| [4] |
B. Zhang, Y. Dong, Y. Zhao, and X. Qi, “DynPL-SLAM: A robust stereo visual SLAM system for dynamic scenes using points and lines,” IEEE Trans. Intell. Veh., 2024, DOI: 10.1109/tiv.2024.3415814.
|
| [5] |
K. A. Tsintotas, L. Bampis, and A. Gasteratos, “The revisiting problem in simultaneous localization and mapping: A survey on visual loop closure detection,” IEEE Trans. Intell. Transp. Syst., vol. 23, no. 11, pp. 19929−19953, Nov. 2022. doi: 10.1109/TITS.2022.3175656
|
| [6] |
S. Schubert, P. Neubert, S. Garg, M. Milford, and T. Fischer, “Visual place recognition: A tutorial [tutorial],” IEEE Robot. Autom. Mag., vol. 31, no. 3, pp. 139−153, Sep. 2024. doi: 10.1109/MRA.2023.3310859
|
| [7] |
D. G. Lowe, “Distinctive image features from scale-invariant keypoints,” Int. J. Comput. Vis., vol. 60, no. 2, pp. 91−110, Nov. 2004. doi: 10.1023/B:VISI.0000029664.99615.94
|
| [8] |
H. Bay, A. Ess, T. Tuytelaars, and L. Van Gool, “Speeded-up robust features (SURF),” Comput. Vis. Image Underst., vol. 110, no. 3, pp. 346−359, Jun. 2008. doi: 10.1016/j.cviu.2007.09.014
|
| [9] |
E. Rosten and T. Drummond, “Machine learning for high-speed corner detection,” in Proc. 9th European Conf. Computer Vision, Graz, Austria, 2006, pp. 430−443.
|
| [10] |
M. Calonder, V. Lepetit, C. Strecha, and P. Fua, “BRIEF: Binary robust independent elementary features,” in Proc. 11th European Conf. Computer Vision, Heraklion, Greece, 2010, pp. 778−792.
|
| [11] |
E. Rublee, V. Rabaud, K. Konolige, and G. Bradski, “ORB: An efficient alternative to SIFT or SURF,” in Proc. Int. Conf. Computer Vision, Barcelona, Spain, 2011, pp. 2564−2571.
|
| [12] |
M. Sandler, A. Howard, M. Zhu, A. Zhmoginov, and L.-C. Chen, “MobileNetV2: Inverted residuals and linear bottlenecks,” in Proc. IEEE Conf. Computer Vision and Pattern Recognition, Salt Lake City, USA, 2018, pp. 4510−4520.
|
| [13] |
R. Arandjelovic, P. Gronat, A. Torii, T. Pajdla, and J. Sivic, “NetVLAD: CNN architecture for weakly supervised place recognition,” in Proc. IEEE Conf. Computer Vision and Pattern Recognition, Las Vegas, USA, 2016, pp. 5297−5307.
|
| [14] |
B. Cao, A. Araujo, and J. Sim, “Unifying deep local and global features for image search,” in Proc. 16th European Conf. Computer Vision, Glasgow, UK, 2020, pp. 726−743.
|
| [15] |
P. Weinzaepfel, T. Lucas, D. Larlus, and Y. Kalantidis, “Learning super-features for image retrieval,” Proc. 10th Int. Conf. Learning Representations, 2022, pp. 1−19.
|
| [16] |
M. Cummins and P. Newman, “FAB-MAP: Probabilistic localization and mapping in the space of appearance,” Int. J. Robot. Res., vol. 27, no. 6, pp. 647−665, Jun. 2008. doi: 10.1177/0278364908090961
|
| [17] |
M. Cummins and P. Newman, “Appearance-only SLAM at large scale with FAB-MAP 2.0,” Int. J. Robot. Res., vol. 30, no. 9, pp. 1100−1123, Aug. 2011. doi: 10.1177/0278364910385483
|
| [18] |
D. Gálvez-López and J. D. Tardos, “Bags of binary words for fast place recognition in image sequences,” IEEE Trans. Robot., vol. 28, no. 5, pp. 1188−1197, Oct. 2012. doi: 10.1109/TRO.2012.2197158
|
| [19] |
L. Bampis, A. Amanatiadis, and A. Gasteratos, “Fast loop-closure detection using visual-word-vectors from image sequences,” Int. J. Robot. Res, vol. 37, no. 1, pp. 62−82, Jan. 2018. doi: 10.1177/0278364917740639
|
| [20] |
E. Garcia-Fidalgo and A. Ortiz, “iBoW-LCD: An appearance-based loop-closure detection approach using incremental bags of binary words,” IEEE Robot. Autom. Lett., vol. 3, no. 4, pp. 3051−3057, Oct. 2018. doi: 10.1109/LRA.2018.2849609
|
| [21] |
S. M. A. M. Kazmi and B. Mertsching, “Detecting the expectancy of a place using nearby context for appearance-based mapping,” IEEE Trans. Robot., vol. 35, no. 6, pp. 1352−1366, Dec. 2019. doi: 10.1109/TRO.2019.2926475
|
| [22] |
D. Alahakoon, S. K. Halgamuge, and B. Srinivasan, “Dynamic self-organizing maps with controlled growth for knowledge discovery,” IEEE Trans. Neural Networks, vol. 11, no. 3, pp. 601−614, May 2000. doi: 10.1109/72.846732
|
| [23] |
A. Oliva and A. Torralba, “Modeling the shape of the scene: A holistic representation of the spatial envelope,” Int. J. Comput. Vis., vol. 42, pp. 145−175, May 2001. doi: 10.1023/A:1011139631724
|
| [24] |
K. A. Tsintotas, L. Bampis, and A. Gasteratos, “Modest-vocabulary loop-closure detection with incremental bag of tracked words,” Robot. Auton. Syst., vol. 141, Art. no. 103782, Jul. 2021. doi: 10.1016/j.robot.2021.103782
|
| [25] |
Y. Xu, J. Huang, J. Wang, Y. Wang, H. Qin, and K. Nan, “ESA-VLAD: A lightweight network based on second-order attention and NetVLAD for loop closure detection,” IEEE Robot. Autom. Lett., vol. 6, no. 4, pp. 6545−6552, Oct. 2021. doi: 10.1109/LRA.2021.3094228
|
| [26] |
M. Tan and Q. Le, “EfficientNet: Rethinking model scaling for convolutional neural networks,” in Proc. 36th Int. Conf. Machine Learning, Long Beach, USA, 2019, pp. 6105−6114.
|
| [27] |
S. An, G. Che, F. Zhou, X. Liu, X. Ma, and Y. Chen, “Fast and incremental loop closure detection using proximity graphs,” in IEEE/RSJ Int. Conf. Intelligent Robots and Systems, Macau, China, 2019, pp. 378−385.
|
| [28] |
Y. A. Malkov and D. A. Yashunin, “Efficient and robust approximate nearest neighbor search using hierarchical navigable small world graphs,” IEEE Trans. Pattern Anal. Mach. Intell., vol. 42, no. 4, pp. 824−836, Apr. 2020. doi: 10.1109/TPAMI.2018.2889473
|
| [29] |
S. An, H. Zhu, D. Wei, K. A. Tsintotas, and A. Gasteratos, “Fast and incremental loop closure detection with deep features and proximity graphs,” J. Field Robot., vol. 39, no. 4, pp. 473−493, Jun. 2022. doi: 10.1002/rob.22060
|
| [30] |
K. Zhang, J. Ma, and J. Jiang, “Loop closure detection with reweighting NetVLAD and local motion and structure consensus,” IEEE/CAA J. Autom. Sinica, vol. 9, no. 6, pp. 1087−1090, Jun. 2022. doi: 10.1109/JAS.2022.105635
|
| [31] |
J. Ma, K. Zhang, and J. Jiang, “Loop closure detection via locality preserving matching with global consensus,” IEEE/CAA J. Autom. Sinica, vol. 10, no. 2, pp. 411−426, Feb. 2023. doi: 10.1109/JAS.2022.105926
|
| [32] |
G. Tolias, Y. Avrithis, and H. Jégou, “Image search with selective match kernels: Aggregation across single and multiple images,” Int. J. Comput. Vis., vol. 116, pp. 247−261, Feb. 2016. doi: 10.1007/s11263-015-0810-4
|
| [33] |
S. Jin, X. Dai, and Q. Meng, “Loop closure detection with patch-level local features and visual saliency prediction,” Eng. Appl. Artif. Intell., vol. 120, Art. no. 105902, Apr. 2023. doi: 10.1016/j.engappai.2023.105902
|
| [34] |
B. Zhang, Y. Xian, and X. Ma, “LSGDDN-LCD: An appearance-based loop closure detection using local superpixel grid descriptors and incremental dynamic nodes,” Comput. Electr. Eng., vol. 119, Art. no. 109477, Oct. 2024. doi: 10.1016/j.compeleceng.2024.109477
|
| [35] |
F. Radenović, G. Tolias, and O. Chum, “Fine-tuning CNN image retrieval with no human annotation,” IEEE Trans. Pattern Anal. Mach. Intell., vol. 41, no. 7, pp. 1655−1668, Jul. 2019. doi: 10.1109/TPAMI.2018.2846566
|
| [36] |
S. Lloyd, “Least squares quantization in PCM,” IEEE Trans. Inf. Theory, vol. 28, no. 2, pp. 129−137, Mar. 1982. doi: 10.1109/TIT.1982.1056489
|
| [37] |
A. Bhattacharyya, “On a measure of divergence between two statistical populations defined by their probability distributions,” Bull. Calcutta Math. Soc., vol. 35, pp. 99−109, 1943.
|
| [38] |
K. Mikolajczyk, T. Tuytelaars, C. Schmid, A. Zisserman, J. Matas, F. Schaffalitzky, et al., “A comparison of affine region detectors,” Int. J. Comput. Vis., vol. 65, pp. 43−72, Oct. 2005. doi: 10.1007/s11263-005-3848-x
|
| [39] |
X. Jiang, J. Jiang, A. Fan, Z. Wang, and J. Ma, “Multiscale locality and rank preservation for robust feature matching of remote sensing images,” IEEE Trans. Geosci. Remote Sens., vol. 57, no. 9, pp. 6462−6472, Sep. 2019. doi: 10.1109/TGRS.2019.2906183
|
| [40] |
S. Kotz, T. Kozubowski, and K. Podgórski, The Laplace Distribution and Generalizations: A Revisit with Applications to Communications, Economics, Engineering, and Finance. Boston, USA: Birkhäuser, 2001.
|
| [41] |
C.-C. Chang and C.-J. Lin, “LIBSVM: A library for support vector machines,” ACM Trans. Intell. Syst. Technol., vol. 2, no. 3, Art. no. 27, Apr. 2011.
|
| [42] |
A. Geiger, P. Lenz, and R. Urtasun, “Are we ready for autonomous driving? The KITTI vision benchmark suite,” in Proc. IEEE Conf. Computer Vision and Pattern Recognition, Providence, USA, 2012, pp. 3354−3361.
|
| [43] |
A. J. Glover, W. P. Maddern, M. J. Milford, and G. F. Wyeth, “FAB-MAP + RatSLAM: Appearance-based SLAM for multiple times of day,” in IEEE Int. Conf. Robotics and Automation, Anchorage, USA, 2010, pp. 3507−3512.
|
Figures(9) / Tables(5)




 DownLoad: